Merge with gap / metering
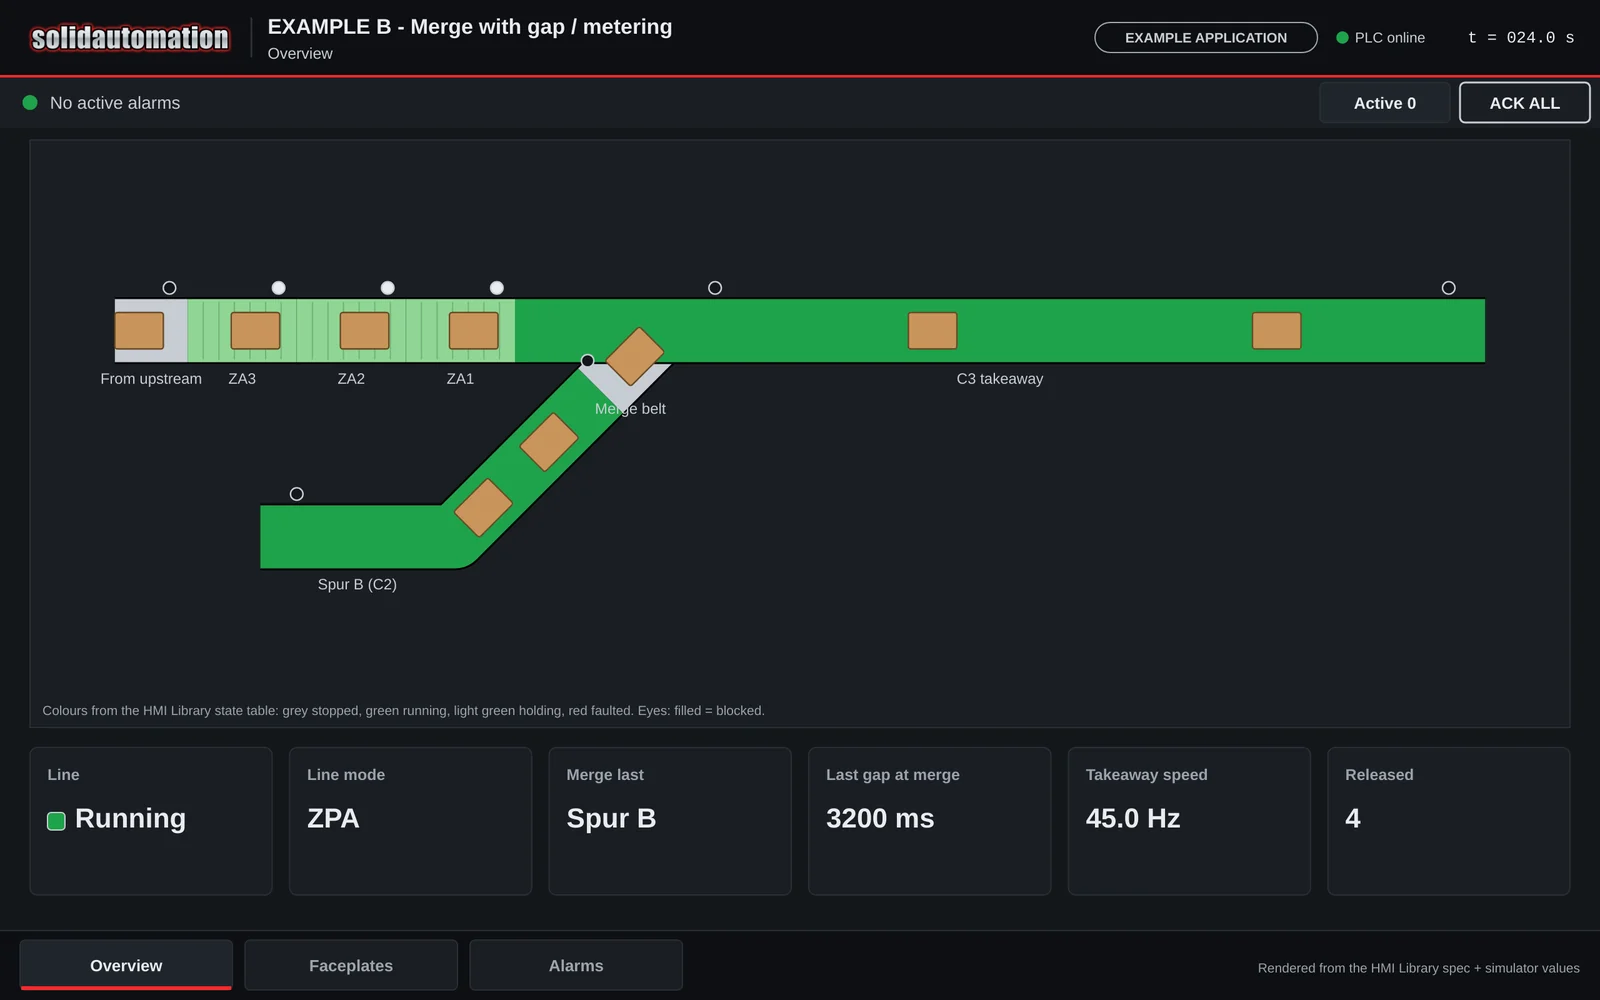
Two infeeds share one takeaway: line A (three ZPA zones) and spur B (a belt on a contactor) joining from the side at 45°, merging onto a takeaway driven by a PowerFlex 525.
Watch the simulator run.
A top view replayed from the simulator run: carton positions and the program's signals every 100 ms.
Recorded from the simulator run of the example program (same rung text as the L5X) against a simple carton model. Cartons drawn at their true 400 × 300 mm footprint.
How the parts work together.
- SOL_Merge decides who goes next, alternating (zipper) when both have a carton waiting.
- SOL_Gap watches the merge eye and only reports the merge clear once the minimum gap has passed since the last carton, so every release is metered.
- The example program adds a merge-transit latch: set on release, cleared only when that carton reaches the merge eye, so nothing is released into a carton still travelling to the merge. A 6 s timeout raises a merge-jam alarm instead of clearing it.
- Each release hands over exactly one carton (it ends on the infeed eye's trailing edge); the other infeed holds at its discharge eye, clear of the merge.
Results.
In the simulator run, 12 releases (ABABABABAAAA) alternated A/B every time both infeeds were waiting, and line A took every slot once spur B ran dry. Every gap at the merge eye met the 600 ms setpoint (3.0 to 3.2 s measured), and a 2-D footprint check across both infeeds found no overlapping cartons. Throughput in this run was about 19.5 cartons a minute, because each release waits for the previous carton to reach the merge eye.
Tested in simulation; not yet run on a controller.
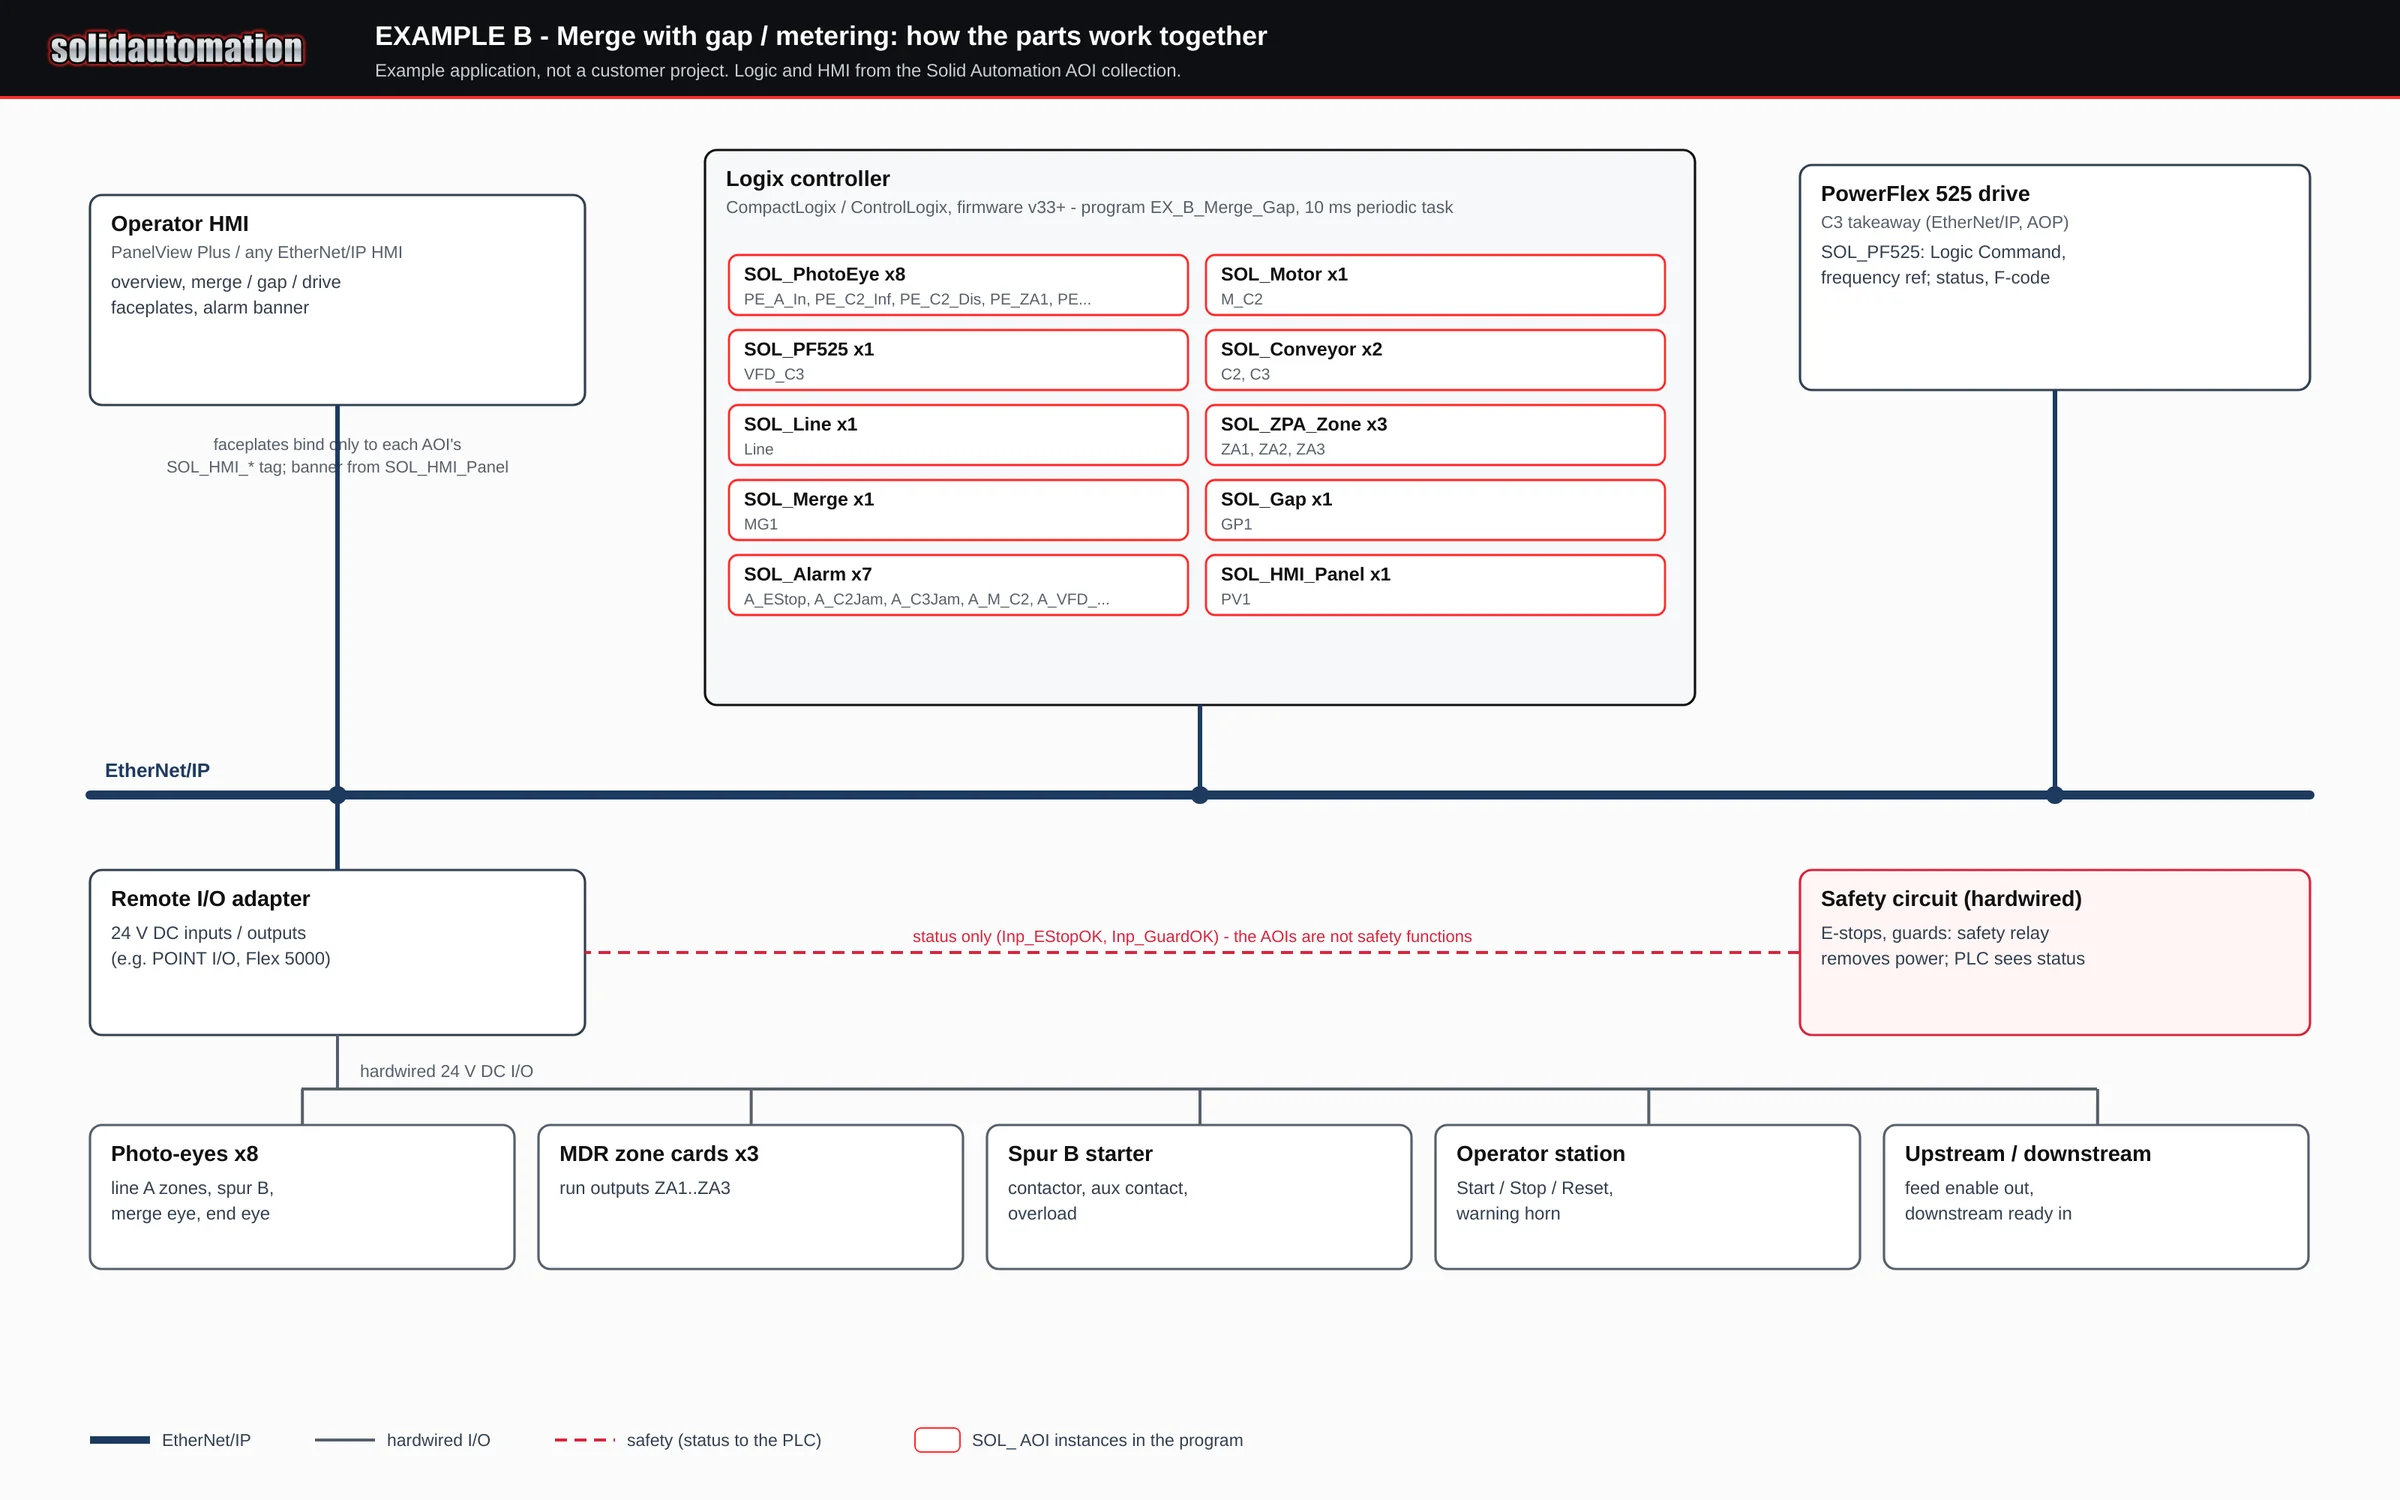
PLC, AOI instances, field devices, HMI.
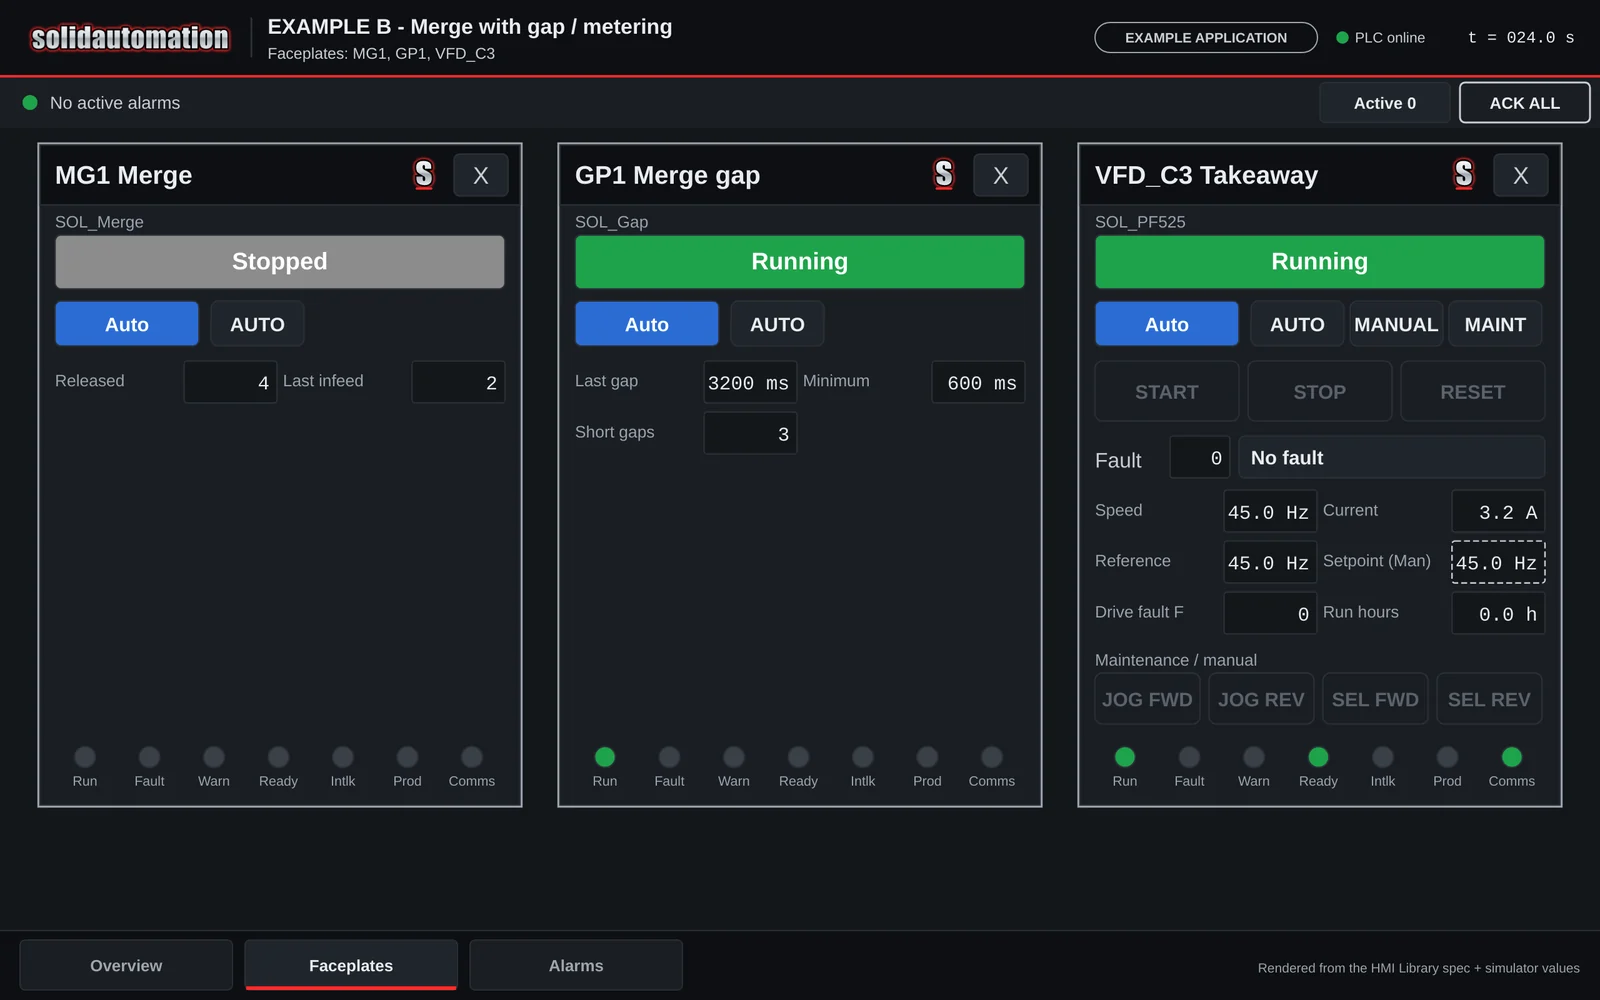
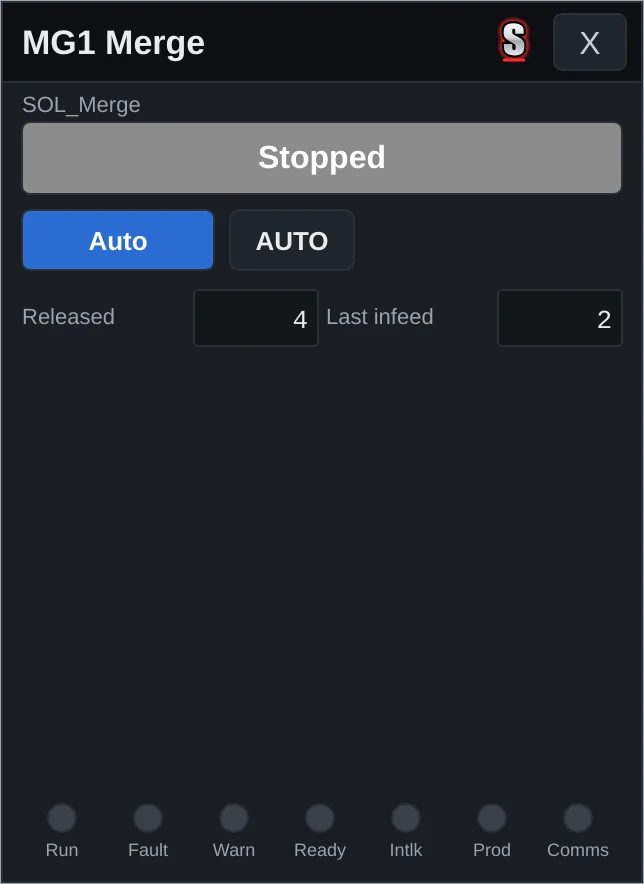
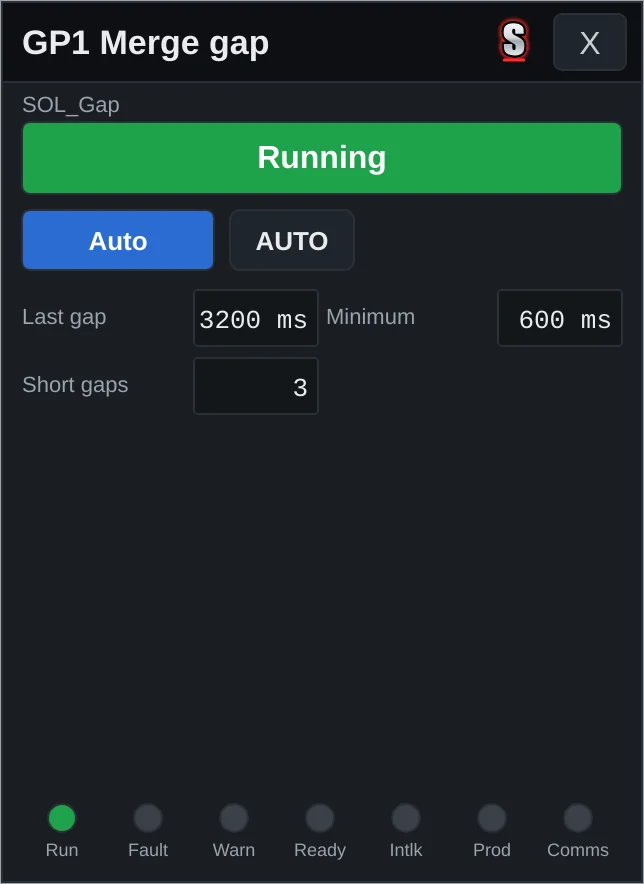
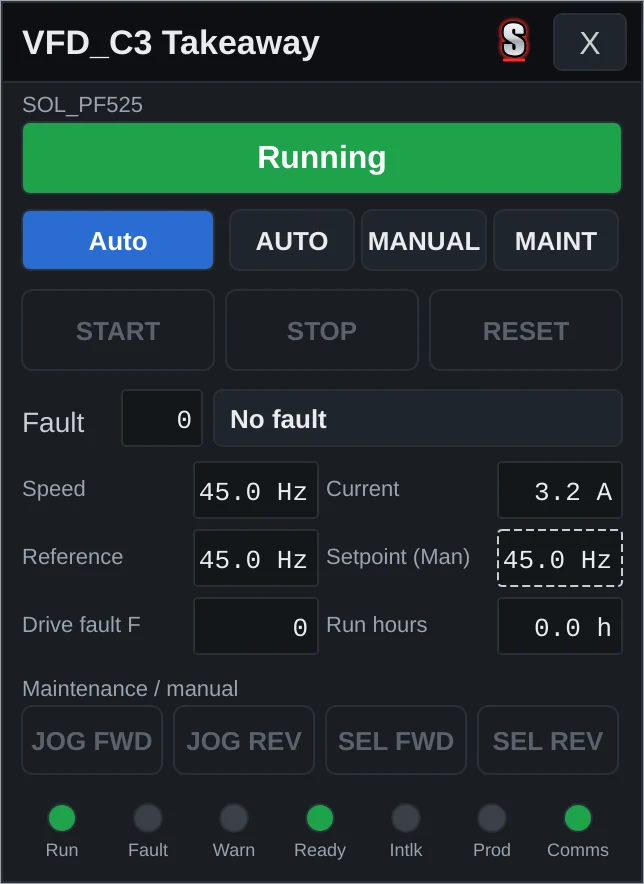
HMI screens and faceplates.
Rendered from the HMI Library definitions with values from the simulator run.