
Robot palletizer infeed
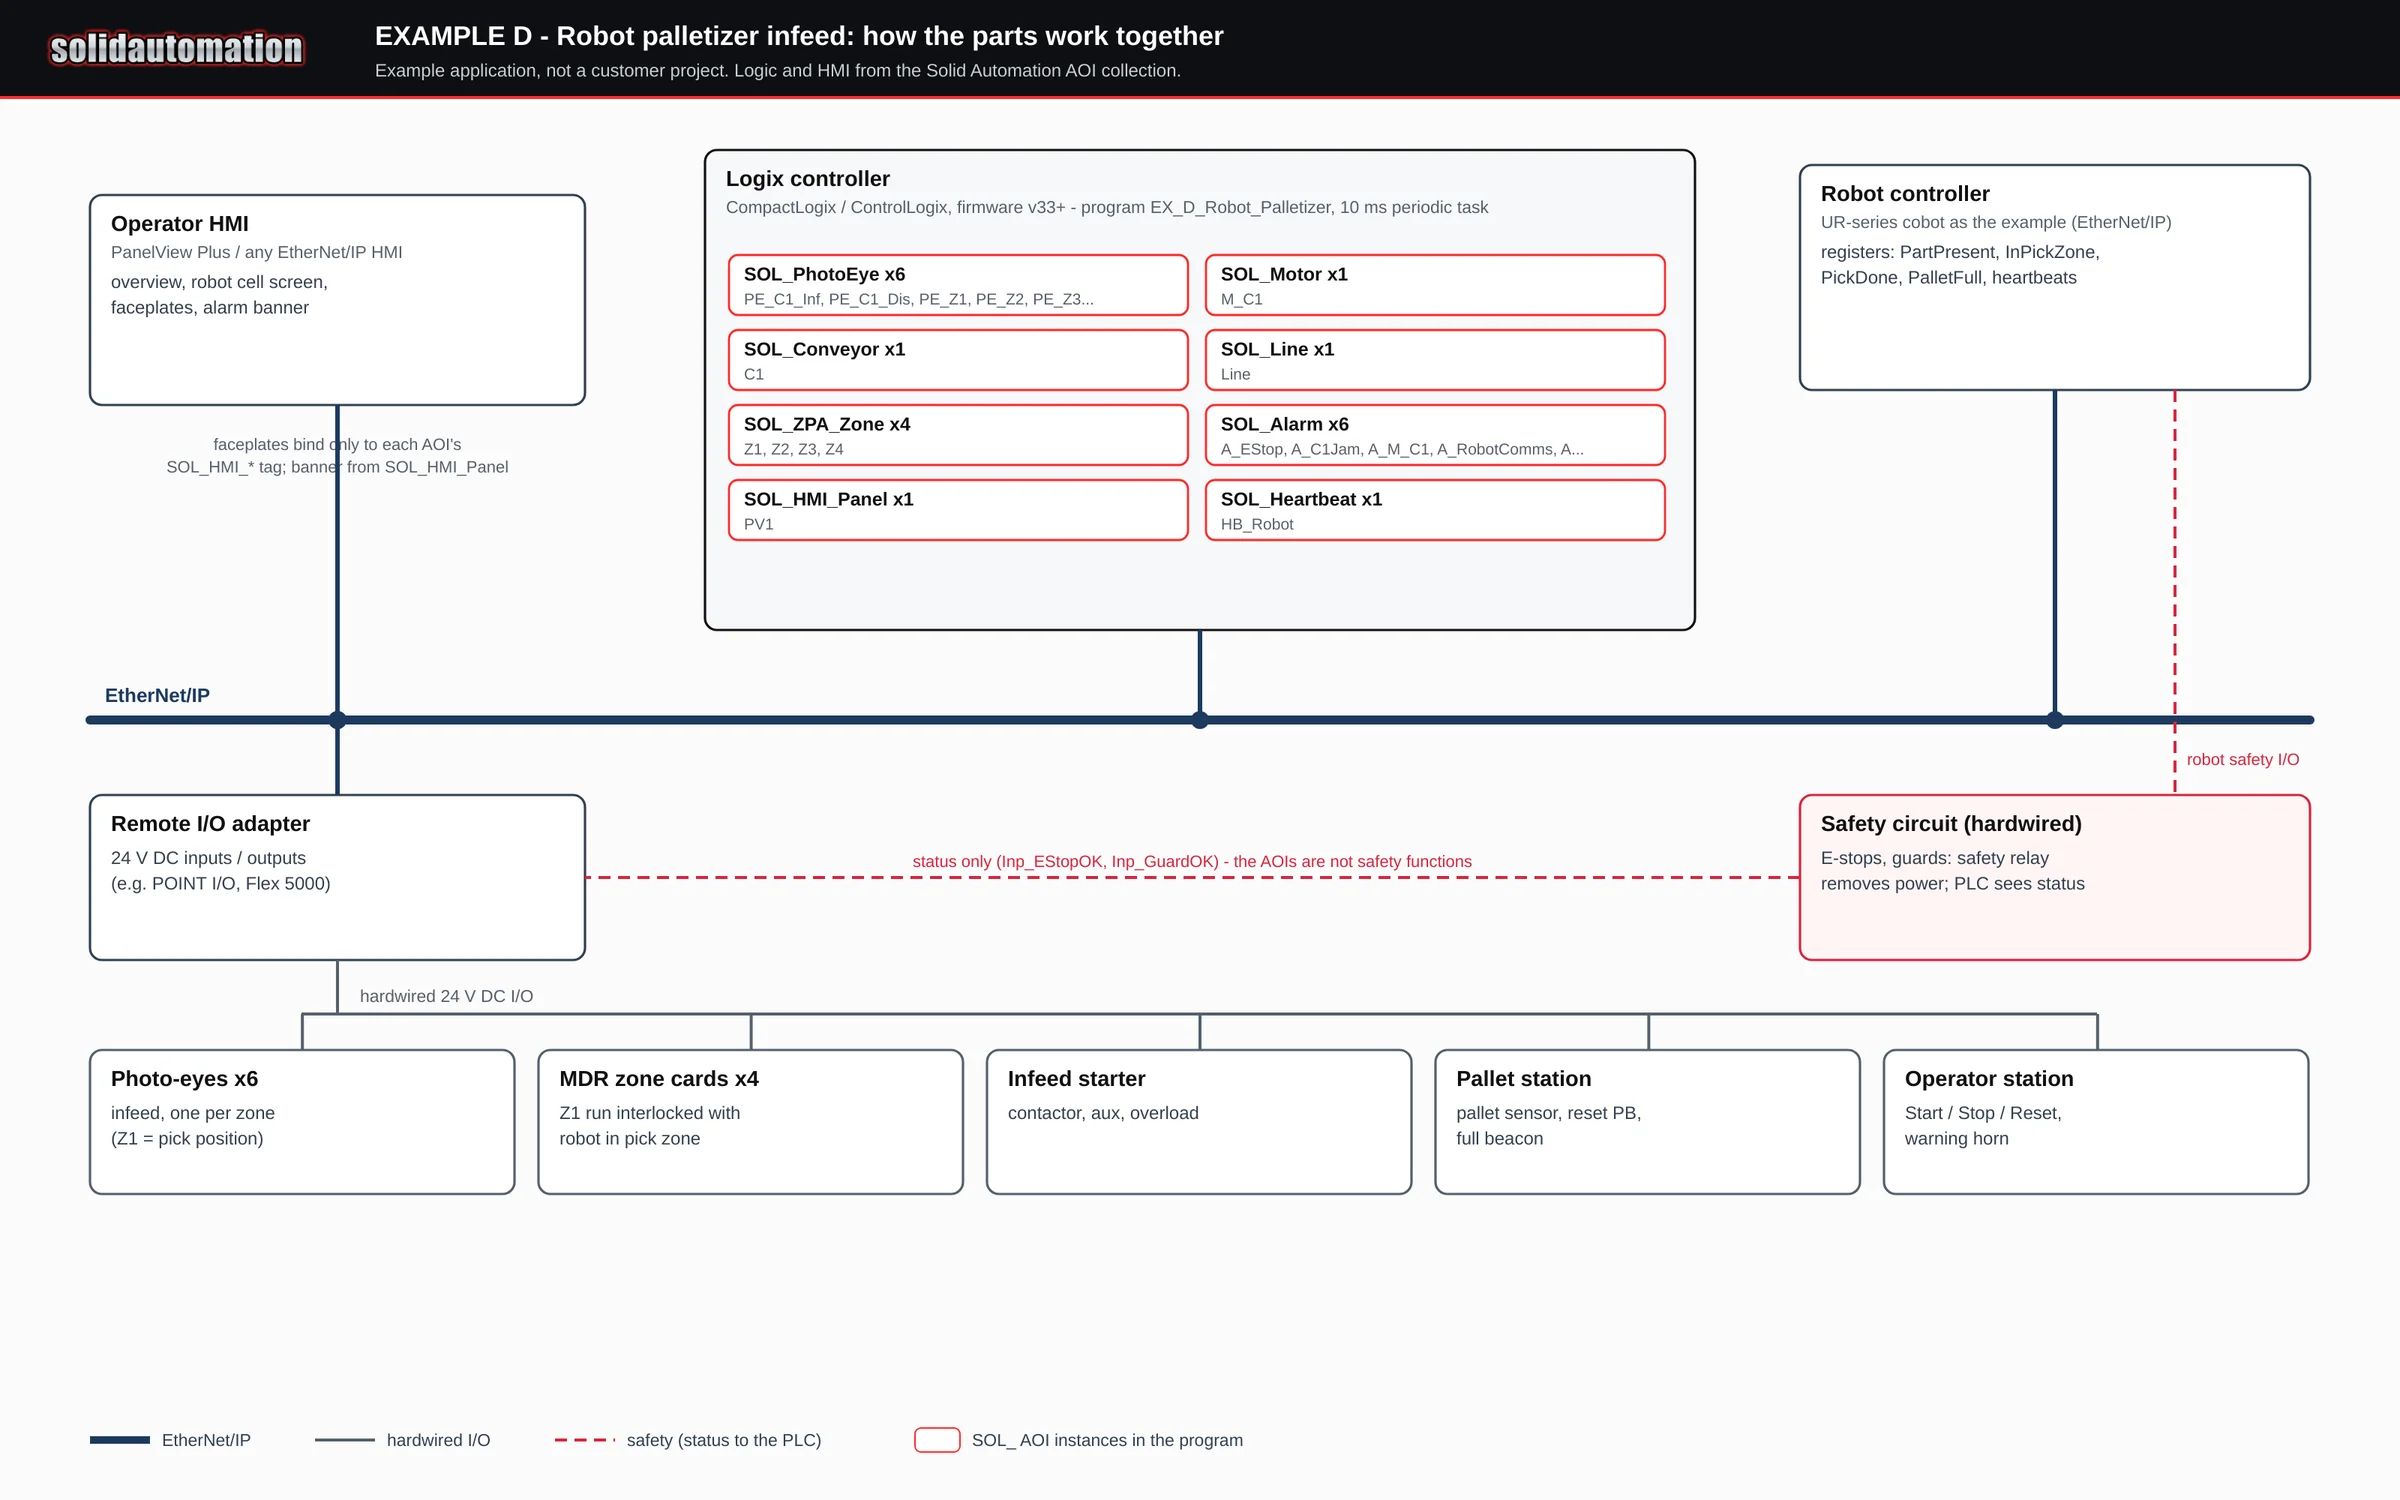
An infeed belt and three ZPA zones bring cartons to a pick zone (a discharge zone that never releases), where a collaborative robot (a Universal Robots UR-series as the example) picks them onto a 2 × 3, two-layer pallet.
Watch the simulator run.
A top view replayed from the simulator run: carton positions and the program's signals every 100 ms.
Recorded from the simulator run of the example program (same rung text as the L5X) against a simple carton model. Cartons drawn at a nominal size.
How the parts work together.
- The PLC raises PartPresent when a carton has settled.
- The robot reports InPickZone while its tool is over the conveyor, and the PLC will not run the pick zone during that time.
- The robot reports PickDone after lifting the carton.
- The PLC drops PartPresent once the eye clears, and the robot drops PickDone, ready for the next cycle.
SOL_Heartbeat watches the robot's heartbeat and withdraws the cycle enable if it stops. Pallet full raises a beacon and an alarm, and the operator confirms the empty pallet before the robot continues. The robot register names in this example are stand-ins, to be mapped to the real robot on site.
Results.
In the simulator run, 18 cartons were picked at a 4.0 s cycle (15 picks per minute), with one full pallet swapped by the operator. The pick zone never moved while the robot was in it. A deliberately stopped robot heartbeat raised "Robot communication lost" within 1.9 s.
Tested in simulation; not yet run on a controller.
PLC, AOI instances, field devices, HMI.
HMI screens and faceplates.
Rendered from the HMI Library definitions with values from the simulator run.
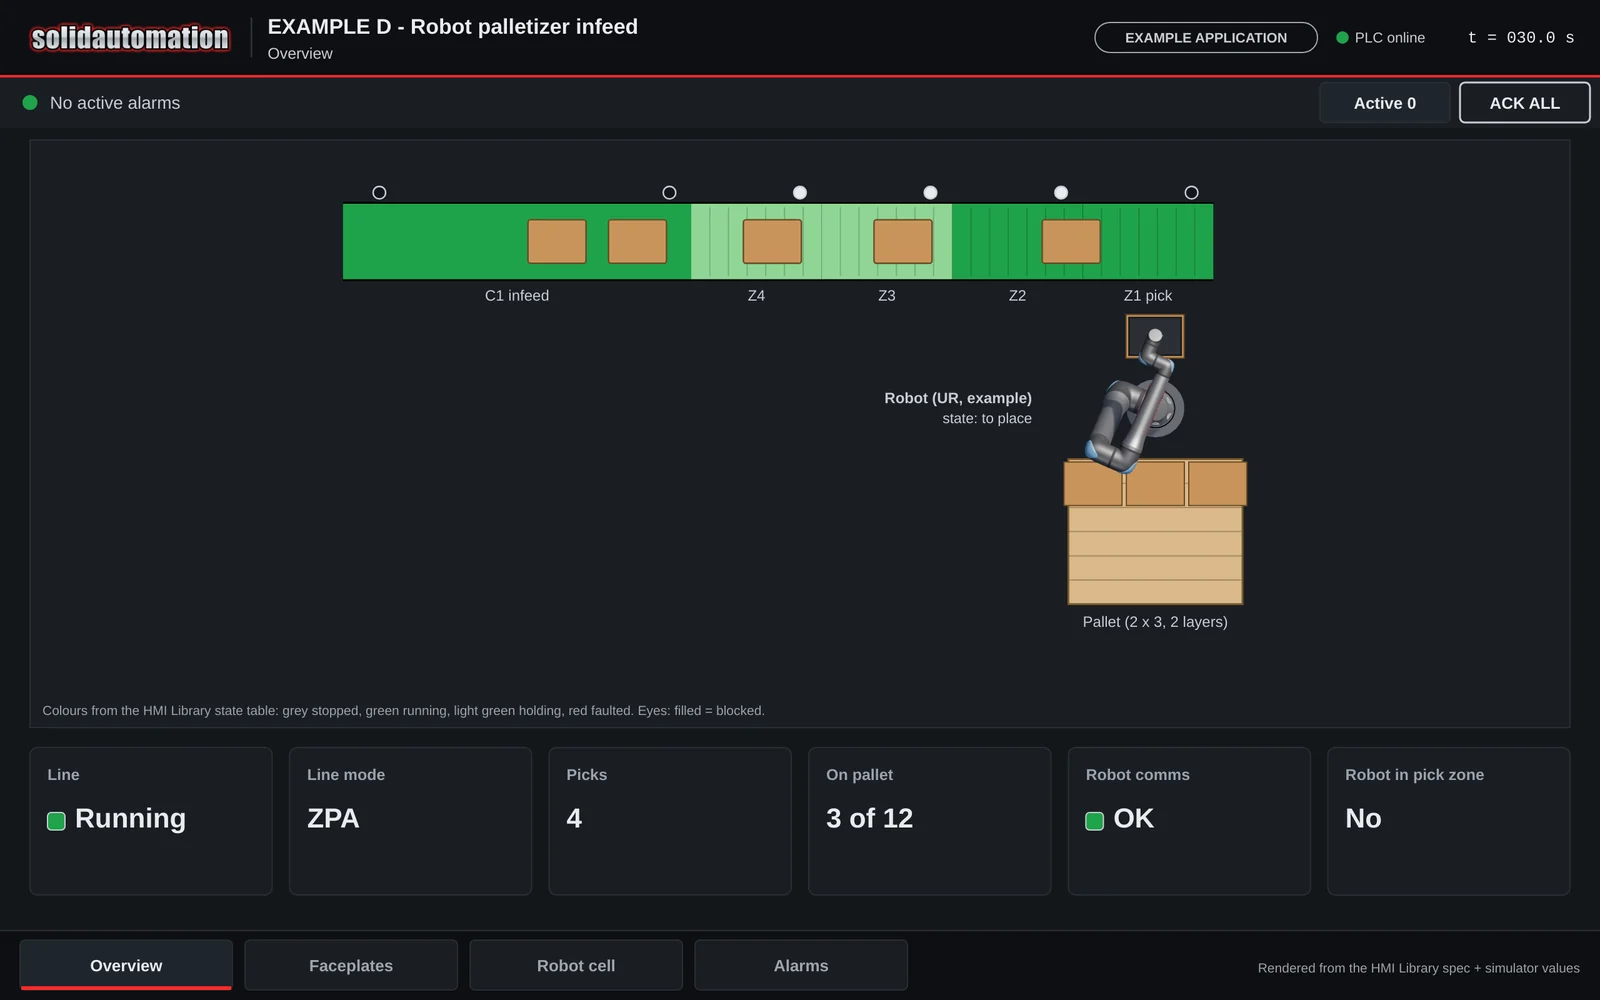 HMI Overview: robot picking from zone 1 and building the pallet.
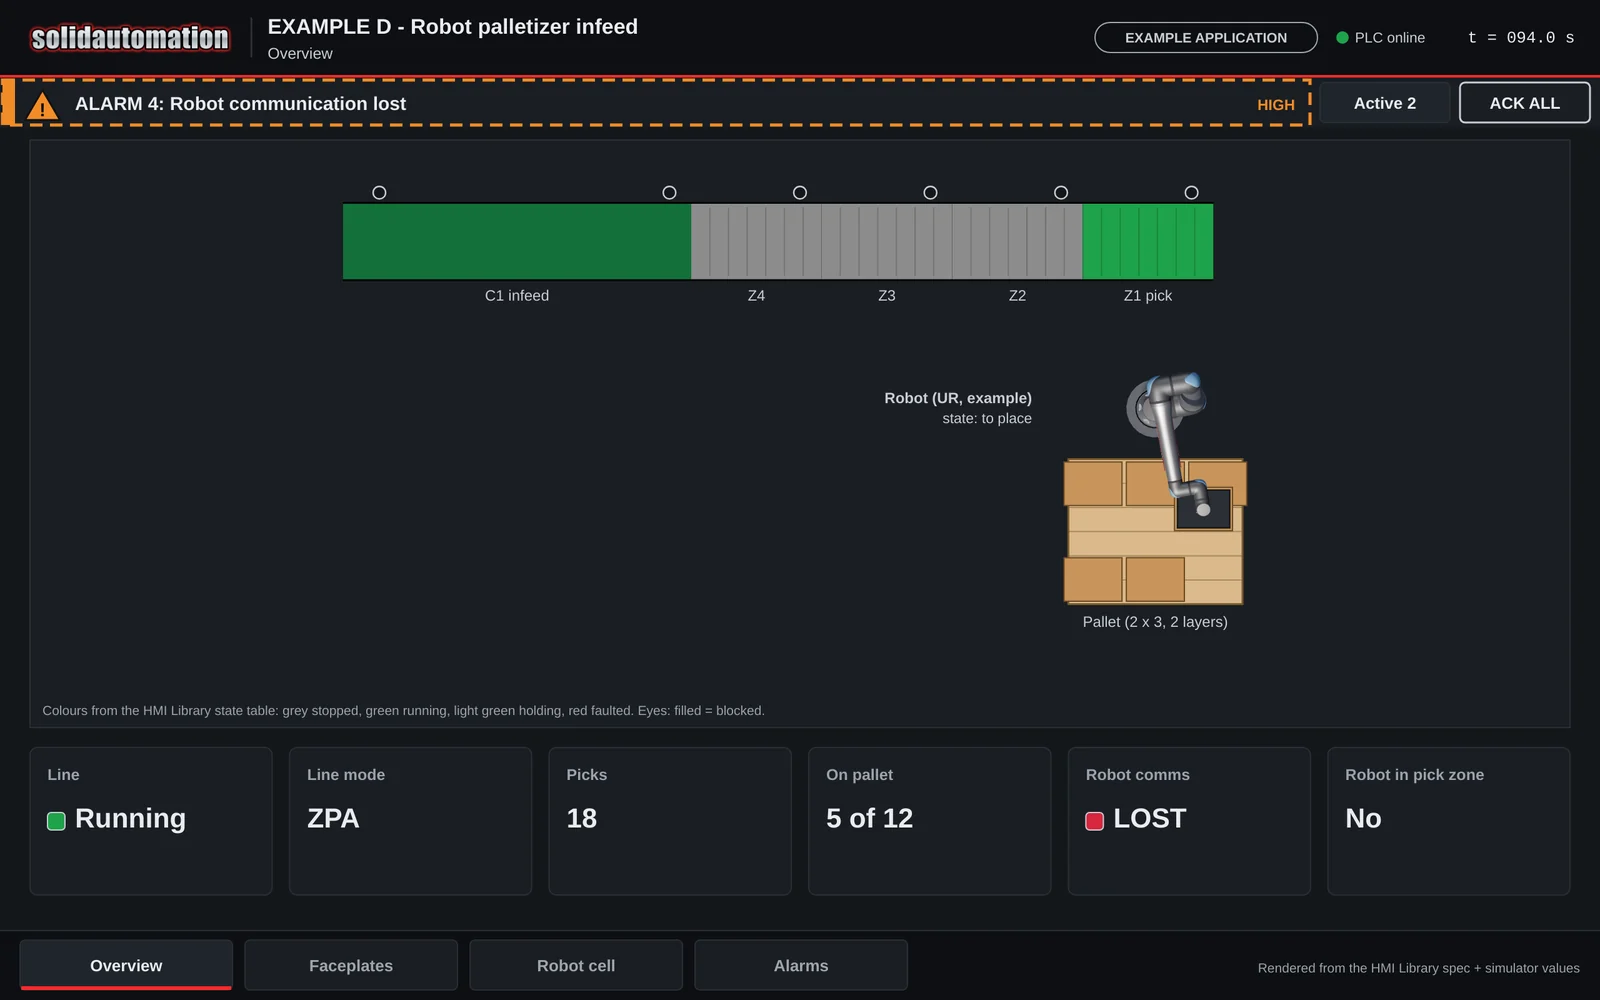 HMI Overview: robot communication lost (banner), cycle enable withdrawn.
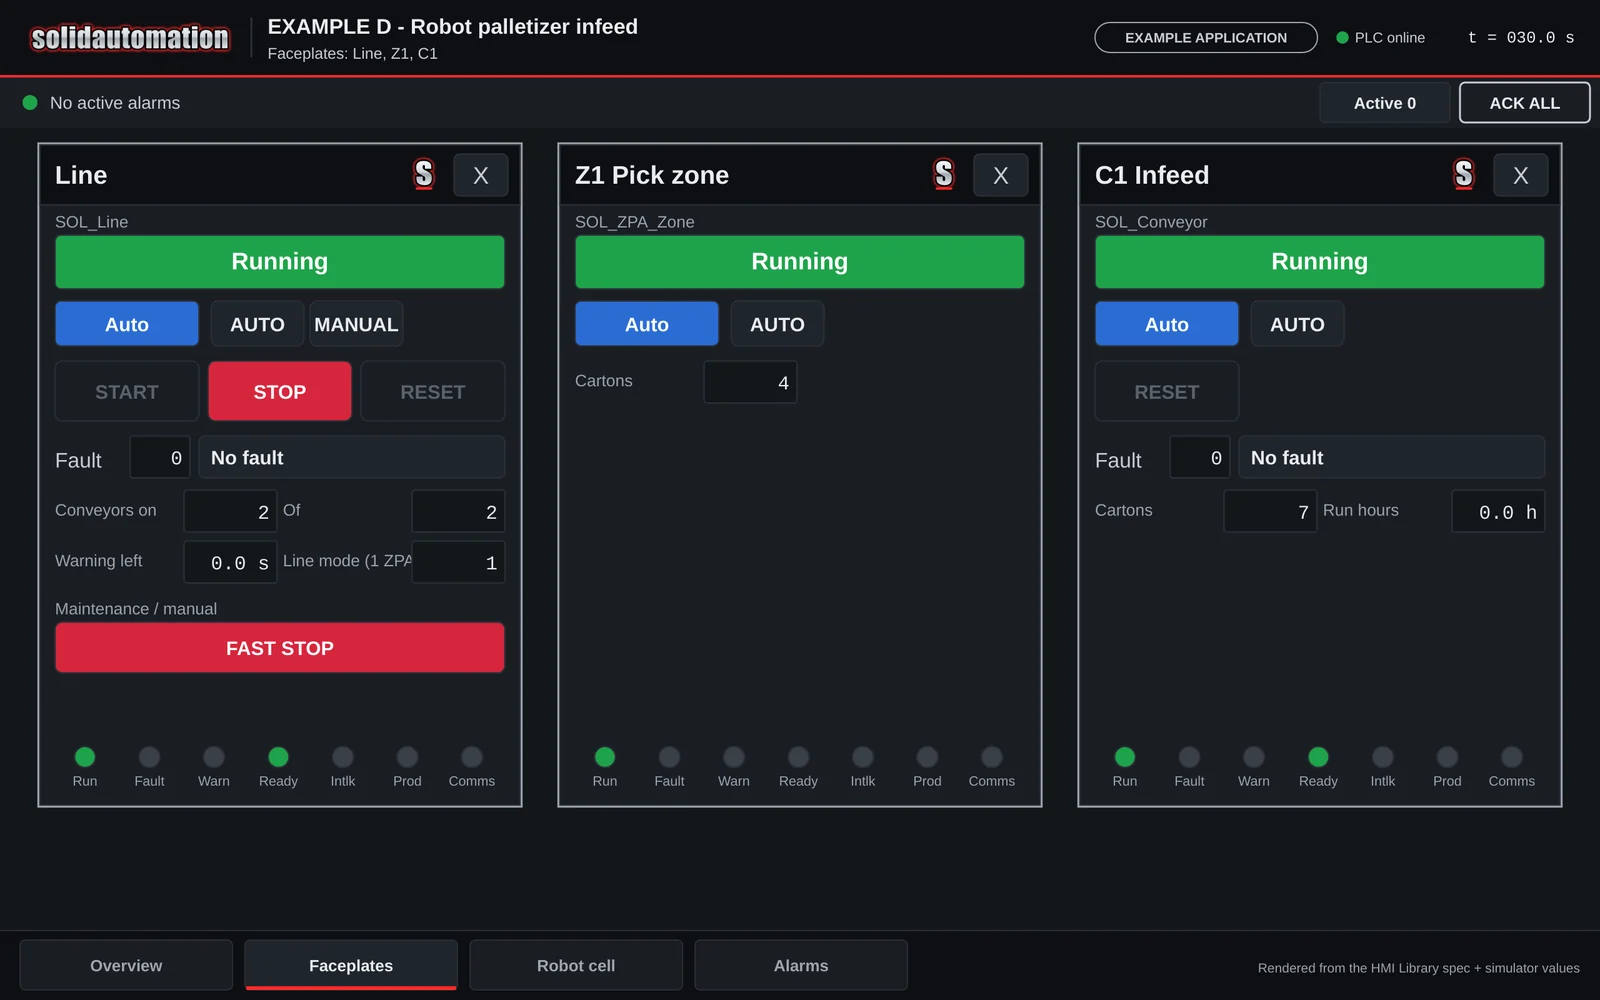 HMI faceplates Line, Z1, C1
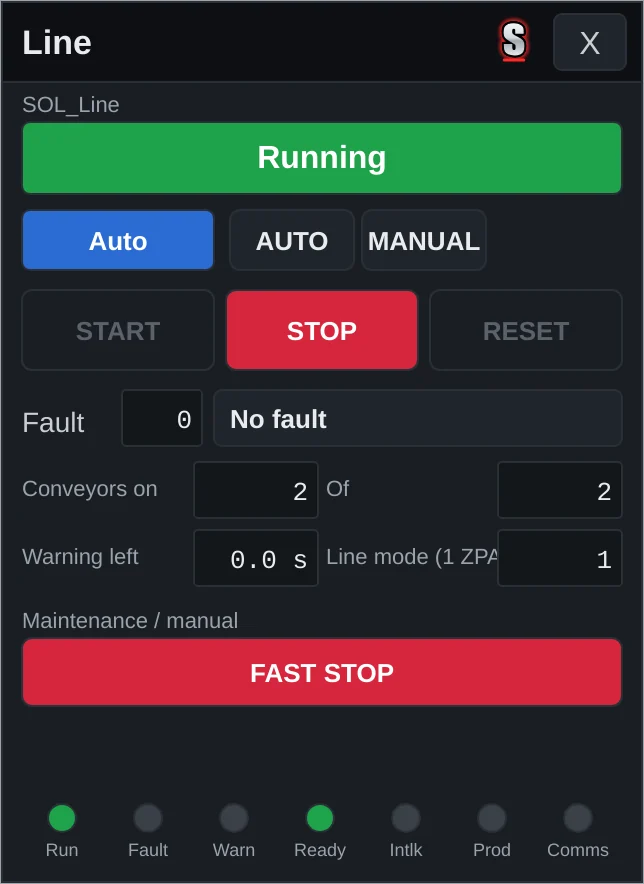 Faceplate Line (SOL_Line) from the HMI Library.
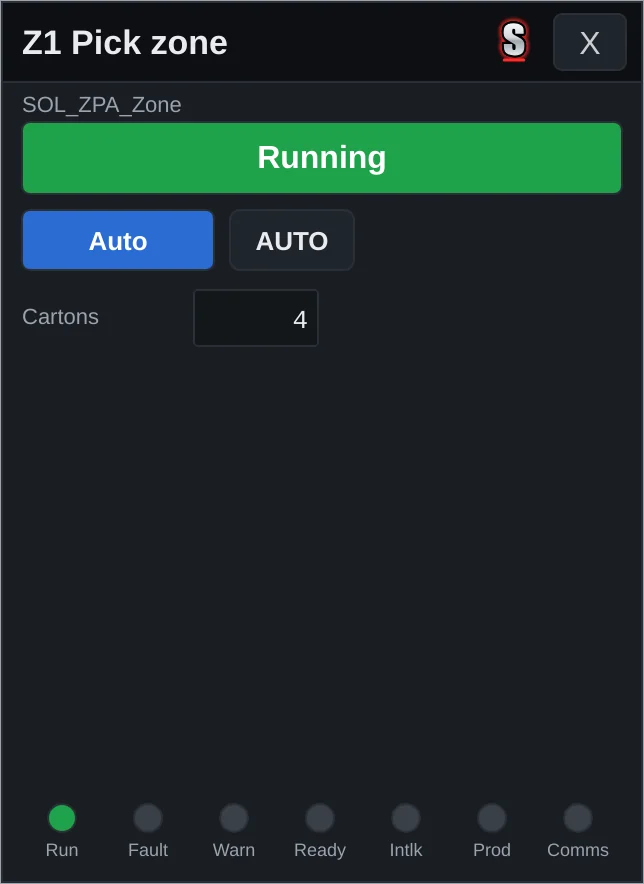 Faceplate Z1 (SOL_ZPA_Zone) from the HMI Library.
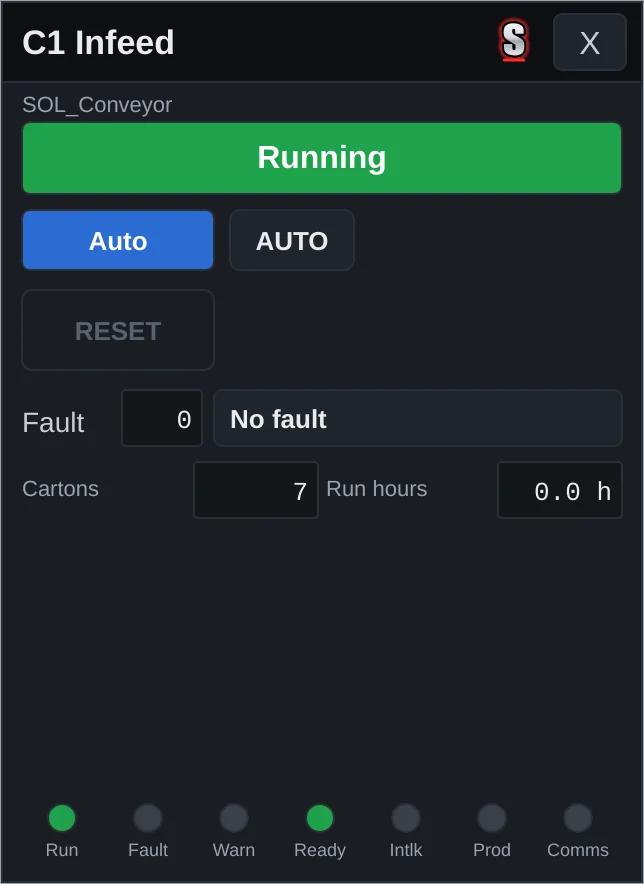 Faceplate C1 (SOL_Conveyor) from the HMI Library.
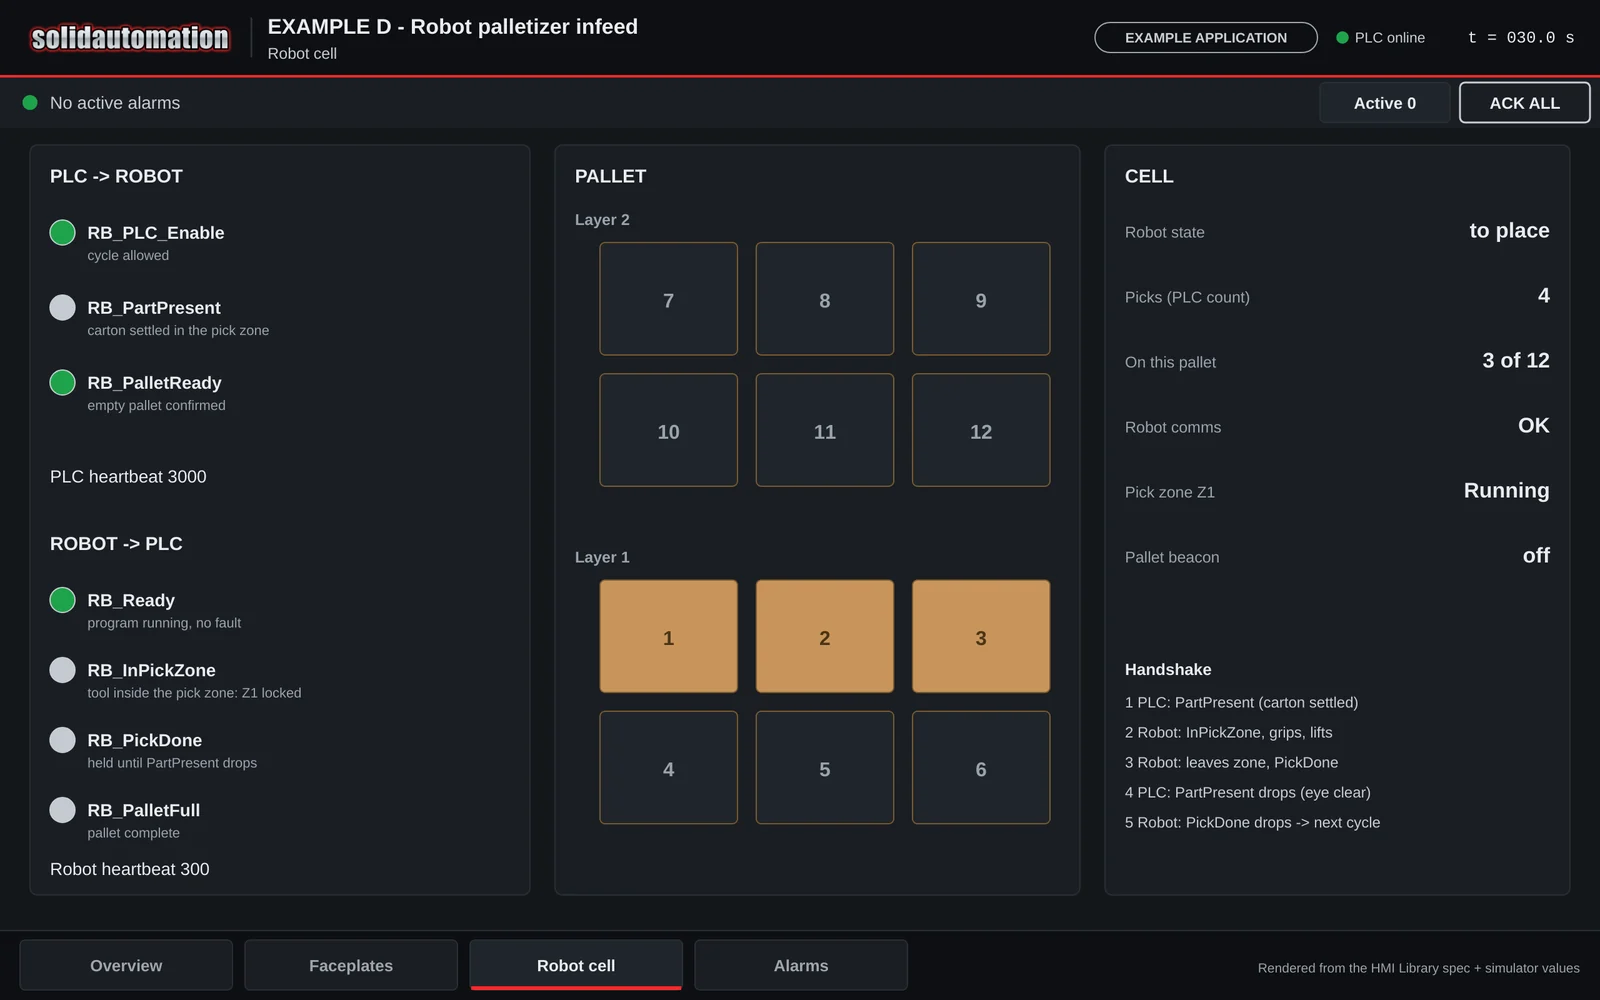 HMI Robot cell: the handshake signals both ways, pallet map, counters…